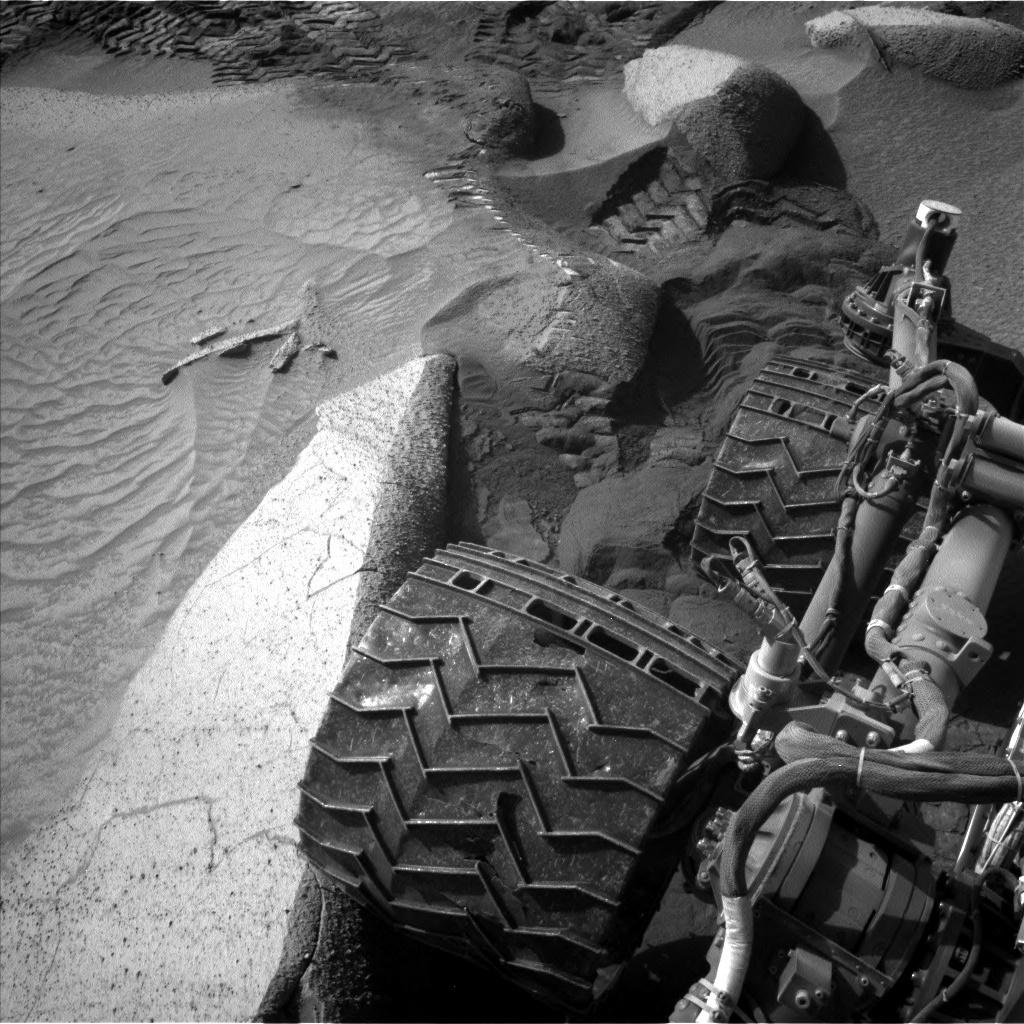
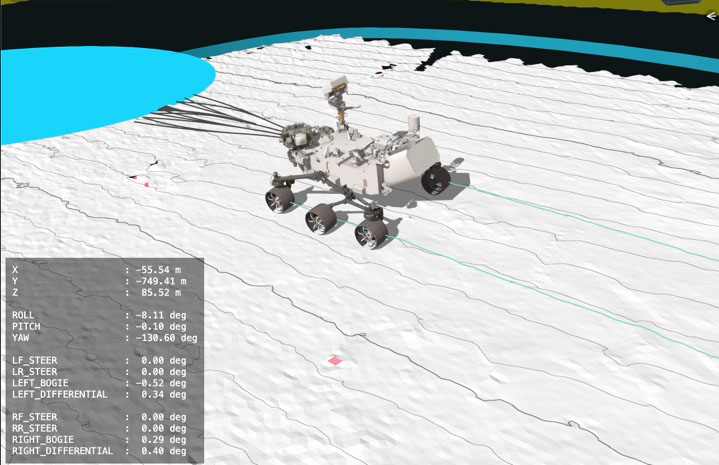
Planetary rovers face significant mobility challenges on loose extraterrestrial terrains, making sand entrapment a critical threat. In this Lab Breakdown, we decode the science of Rover Slip Estimation. By benchmarking visual odometry derived from optical flow against the tangential velocity measured by wheel encoders, we explore how single-wheel testbeds isolate and quantify traction loss. This technical analysis of hardware integration and ROS 2 nodes is essential for developing robust hazard avoidance. Discover how autonomous systems detect wheel slip to survive the unpredictable surfaces of the Moon and Mars.
The lunar exploration paradigm is shifting from multi-billion-dollar, Rad-Hard institutional rovers to agile, modular platforms built with COTS components. To compensate for strict SWaP constraints and reduced sensor redundancy, commercial vehicles like SAS’s LUVMI-X, Astrobotic’s CubeRover, and Australia’s Roo-ver rely on aggressively optimized software. By leveraging Light-Weight SLAM, Visual Odometry, and calculated algorithmic risk for high-tempo Hazard Avoidance, these software-defined rovers act as the automated logistics infrastructure for the emerging cis-lunar economy. This transition proves that scalable autonomous navigation is no longer a scientific luxury, but an indispensable engineering commodity for sustained In-Situ Resource Utilization (ISRU).
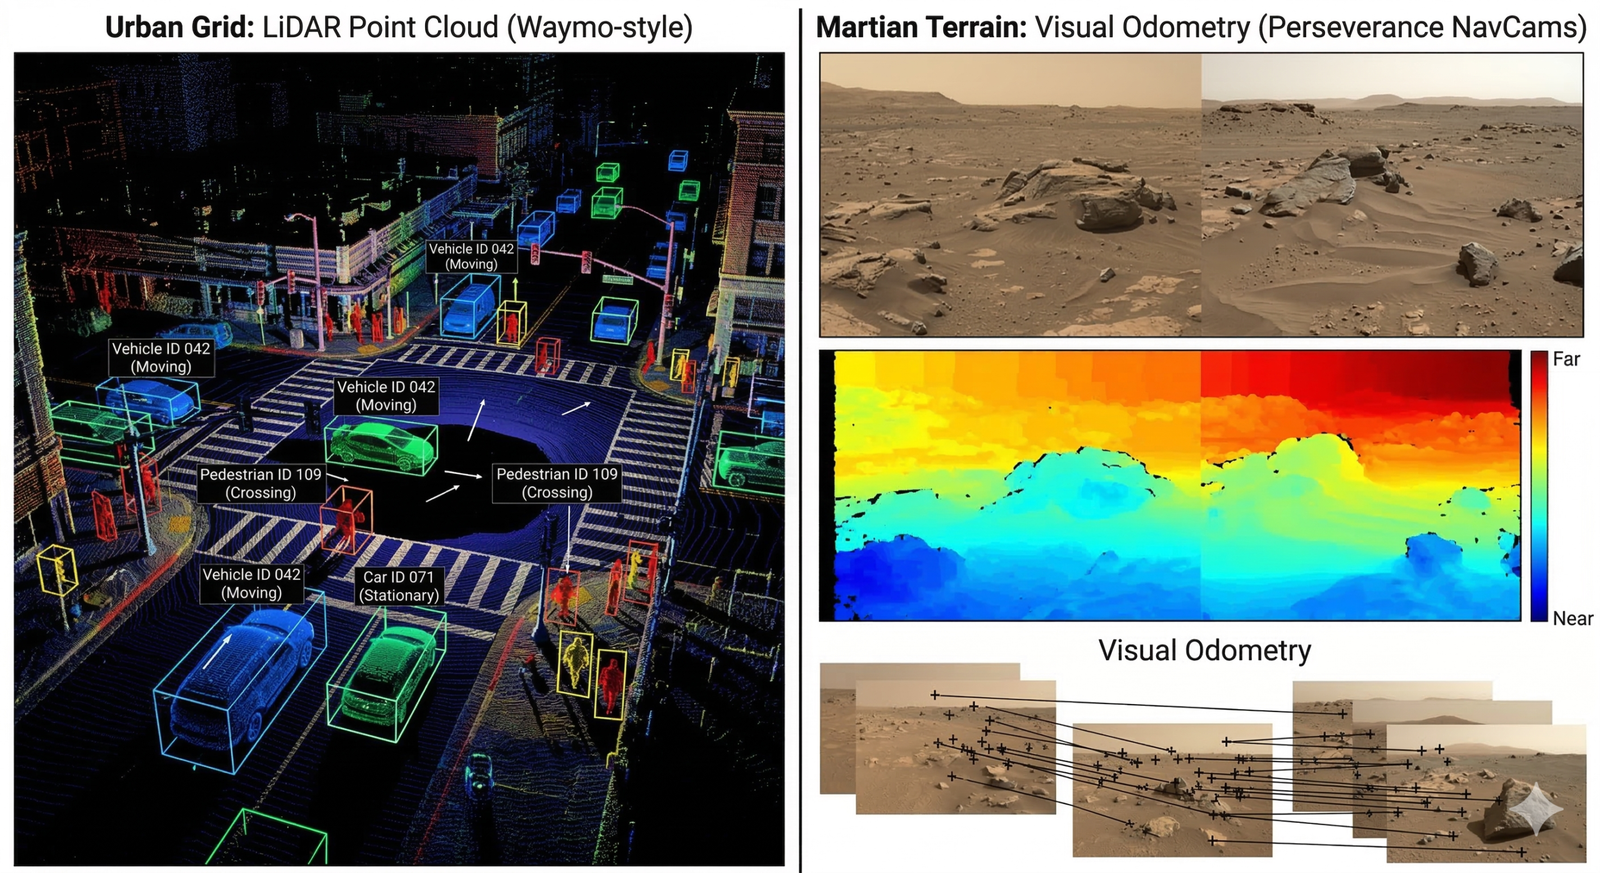
The convergence of terrestrial autonomous vehicles and planetary rovers reveals profound algorithmic and architectural intersections. While self-driving cars process immense data using high-performance processors in structured environments, space rovers navigate unstructured, high-radiation terrains constrained by severe power limits and communication latency, historically relying on legacy rad-hardened hardware. Today, this paradigm is shifting. The aerospace sector is actively integrating automotive Deep Reinforcement Learning, hybrid computing, and photorealistic simulations to achieve robust autonomous navigation. Conversely, the automotive industry leverages space-proven fault-tolerance and remote teleoperation strategies to master complex urban edge cases, driving a mutual evolution in robotics.
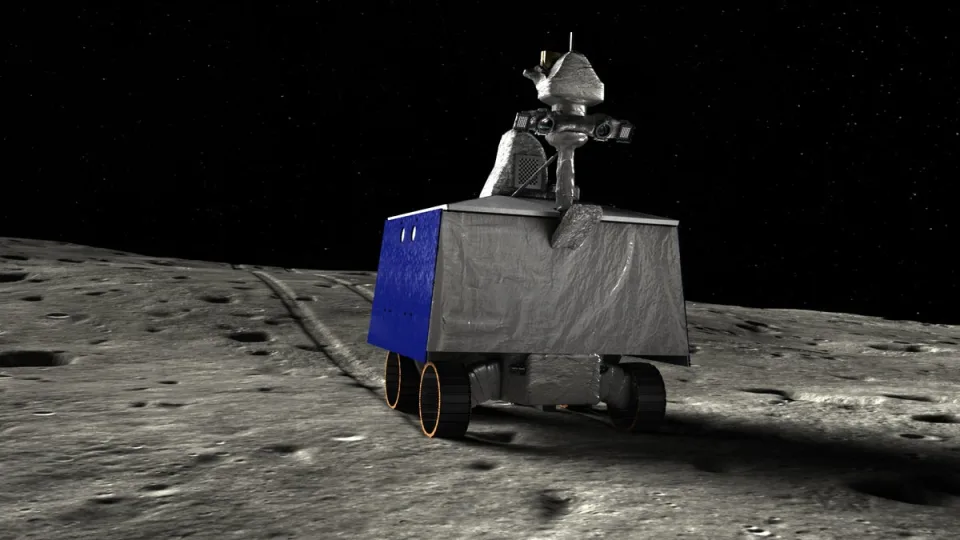
This article provides a comprehensive engineering review of the VIPER rover AI navigation system, designed for the extreme conditions of lunar Permanently Shadowed Regions (PSRs). Resurrected for a 2027 Blue Origin launch, VIPER abandons traditional passive solar navigation. Instead, it employs active LED illumination and robust visual odometry to counteract dynamic shadowing. To ensure survival in cryogenic darkness, the architecture leverages computationally efficient grid-based algorithms like D* Lite for real-time hazard avoidance and Extended Kalman Filters (EKF) for precise kinematic slip estimation on porous regolith. Ultimately, VIPER’s hybrid "Earth-in-the-Loop" autonomy establishes the technical baseline for future Artemis surface operations.
Space telemetry analysis is shifting from reconstruction-based models like TadGAN to Zero-Shot Anomaly Detection. Traditional generative models struggle in deep space, suffering from overfitting and failing to identify unprecedented operational faults. The TimeRCD framework introduces a paradigm shift via the Relative Context Discrepancy (RCD) approach. Instead of reconstructing nominal data, TimeRCD measures vector discrepancies between local and global temporal contexts using pre-trained Foundation Models. Validated on NASA's SMAP and MSL datasets, this zero-shot architecture drastically cuts false positives, reduces computational loads on Rad-Hard processors, and paves the way for true onboard spacecraft autonomy.
This technical report analyzes the pivotal event of Sol 1707-1709, where Perseverance navigated Mars guided by the Claude Code AI agent. For the first time, an LLM was integrated into the critical path, generating executable Rover Markup Language (RML) code. This "Ground-in-the-Loop" paradigm transcends traditional AutoNav limitations through semantic terrain analysis and terrestrial computing power. Rigorously validated via Digital Twin simulation, the AI successfully directed 456 meters of autonomous driving. This milestone demonstrates Generative AI's capacity to control physical assets in critical environments, redefining space exploration standards.
Why doesn't NASA use standard self-driving car sensors on Mars Rovers? It seems cost-effective, but the reality is harsh. This article dives into the Automotive vs. Space LiDAR debate, analyzing why terrestrial tech—like Luminar’s Iris—fails off-planet. We break down the engineering nightmares of space: deadly cosmic radiation, vacuum outgassing, and extreme thermal cycles that shatter standard electronics. By comparing commercial efficiency against NASA’s reliability, we explain why "good enough" for Earth is fatal on Mars. Plus, discover the surprising exception where a $129 drone part actually made it to the Red Planet.
his analysis explores the technical architecture of China's Zhurong rover, highlighting how it differs from NASA's design philosophy. Operating in Utopia Planitia, Zhurong utilizes a hierarchical pathfinding system that combines $A^*$ for global route planning with $D^*$ Lite for dynamic obstacle avoidance. To survive without nuclear power, it employs autonomous "wake/sleep" algorithms based on environmental conditions. Furthermore, the rover mitigates dangerous high-slip interactions using unique active suspension capable of "inchworm" motion and crab walking, allowing it to successfully map geology and hydrated minerals far beyond its nominal 90-sol lifespan.
Abstract: The Odometer Fallacy on Mars On Earth, measuring distance is a trivial task. A vehicle’s odometer counts wheel rotations, multiplies by the circumference, and derives the distance traveled with high precision. On Mars, however, this deterministic logic collapses.
In the chaotic, non-geometric terrain of the Red Planet, wheel rotation does not equal linear motion.
This article examines autonomous navigation on Mars, where rovers like Perseverance face severe hardware constraints (200 MHz CPUs). We conduct a technical comparison between A*, the deterministic standard for static global planning, and D Lite*, the superior choice for dynamic replanning. While A* forces computationally expensive recalculations for every new obstacle, D* Lite utilizes incremental updates ($rhs-values$) to optimize processing time. By analyzing Cost Maps and algorithmic complexity, we demonstrate how the evolution toward Field D* and Hybrid AI is critical for safe robotic exploration.
This article analyzes Rover Perception, explaining how Stereo Vision, LiDAR, and IMUs integrate to enable autonomous navigation. It details the role of Sensor Fusion and Extended Kalman Filters in overcoming communication latency. Case studies of Perseverance and VIPER illustrate how these systems map unstructured extraterrestrial environments with precision to ensure mission safety.
Autonomous rover navigation in GPS-denied environments relies on SLAM (Simultaneous Localization and Mapping). This algorithm uses probabilistic filters like EKF and Graph-SLAM to build maps and track position in real-time. Essential for Mars missions, it has evolved from basic visual odometry to advanced sensor fusion for future exploration.
A 20+ minute communication lag makes "joysticking" Mars rovers impossible, unlike the Moon's brief 2.5-second delay. This lag forced technology to evolve: from slow direct signals to high-bandwidth orbiter relays and robotic autonomy (AutoNav). Future lasers will boost data, but the lag remains.
Mars' 20-minute communication latency forced the evolution of rover AI. This article charts the path from Sojourner's simple reactive "bump" system to Spirit's deliberative 2.5D mapping. It covers Curiosity's continuous AutoNav and Perseverance's real-time predictive navigation, which uses a dedicated Vision Compute Element (VCE), showing how hardware unlocks autonomy.
Why can't we joystick a Mars rover? A 26-minute signal lag makes it impossible. This guide explores the necessity of autonomous rover navigation, breaking down the core tech, SLAM, Pathfinding, and Hazard Avoidance. We trace its evolution from Mars to the unique challenges of the Moon, explaining how robots think for themselves.